ENGR202 Summer 2022 Q B2[VALID] official answers
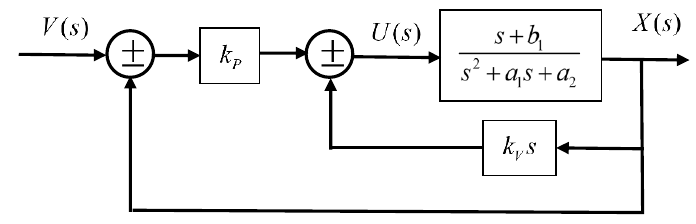
This question concerns the model and control system shown in Figure B2-1.
Formulas you may need
- Steady state gain ; poles from the characteristic equation; quadratic formula (learn this)
- Negative feedback rule: ; series rule: (learn this)
- Pole placement: divide the characteristic equation by the coefficient and match to (learn this)
- Hurwitz for : , , , all (learn this)
- (a)[3]Briefly define and explain what , and refer to. Describe one practical example to illustrate your answer.
- (b)[8]Write down the open loop Transfer Function of the control model shown in Figure B2-1. Develop algebraic expressions to determine the steady state gain and the poles of the control model. Use these expressions to calculate numerical values of both the gain and the poles for the case that , and . Determine the stability condition and dominant pole. Finally, for the same numerical example, what is the steady state value of for an input magnitude of 5?
- (c)[5]Show that the Closed-Loop Transfer Function associated with Figure B2-1 takes the following form:
- (d)[6]For the case that , and , determine the characteristic equation for the Closed-Loop Transfer Function. Design a control system based on Figure B2-1 that achieves a closed-loop damping of 1.0 and a natural frequency of 0.5, i.e. determine suitable values of and .
- (e)[3]Use the Hurwitz method to determine the stability condition of the following, different, characteristic equation: .