ENGR216 Summer 2021 Dynamics Q A3[VALID]
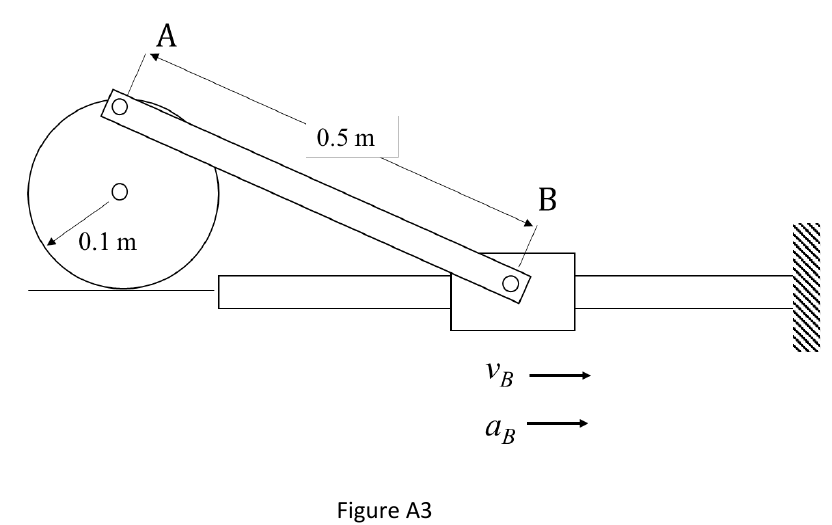
Figure A3 shows a slider mechanism that connects a wheel crank to the slider block B via link arm AB. If slider block B has a velocity m/s to the right, and acceleration , positive to the right as shown in the figure, determine:
Formulas you may need
- Relative velocity: (learn this)
- Relative acceleration: (learn this)
- Rolling without slipping: , ; contact point has zero velocity (learn this)
- Instantaneous centre of zero velocity (IC) method (learn this)
- (a)[3]2:2The angular velocity of link arm AB
- (b)[5]The angular acceleration of link arm AB
- (c)[5]The angular acceleration of the wheel
- (d)[3]ThirdState any assumptions that you have made, with full justification