Old spec 1.4 example, linearised free pendulumTutorialOld spec ENGR2022:28 min

ENGR202 (old spec) Control 1.4 Nonlinear Systems, example linearised model for a free pendulum (slides 11-15)

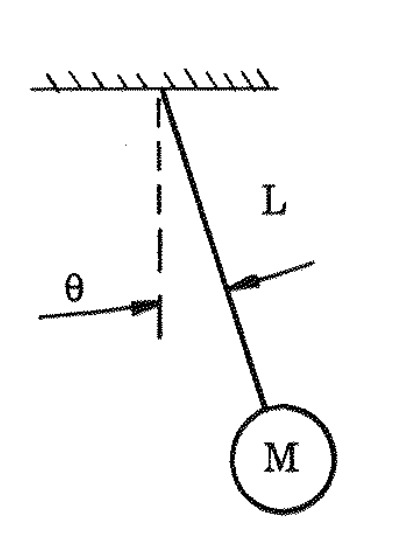
A free pendulum consists of a mass MM on a light rod of length LL, pivoted at the top; θ\theta is the angle of the rod from the vertical (see figure). The restoring torque about the pivot due to gravity is T=MLgsin⁡θT = MLg\sin\theta which is a continuous nonlinear function of θ\theta.

Free pendulum: mass M on a rod of length L, angle theta from the vertical.
Formulas you may need
  • Linearisation about an operating point x0x_0: g(x)≈g(x0)+dgdx∣x=x0(x−x0)g(x) \approx g(x_0) + \left.\dfrac{dg}{dx}\right|_{x = x_0}(x - x_0) (first order Taylor series) (learn this)
  1. (a)
    Linearise the torque about the operating condition θ0=0\theta_0 = 0 using a Taylor series.
  2. (b)
    When is the linear model valid? Find the percentage error in the linearised torque at θ=10\theta = 10 degrees.