ENGR202 (old spec) Control 4.3 Control Objectives, exercise
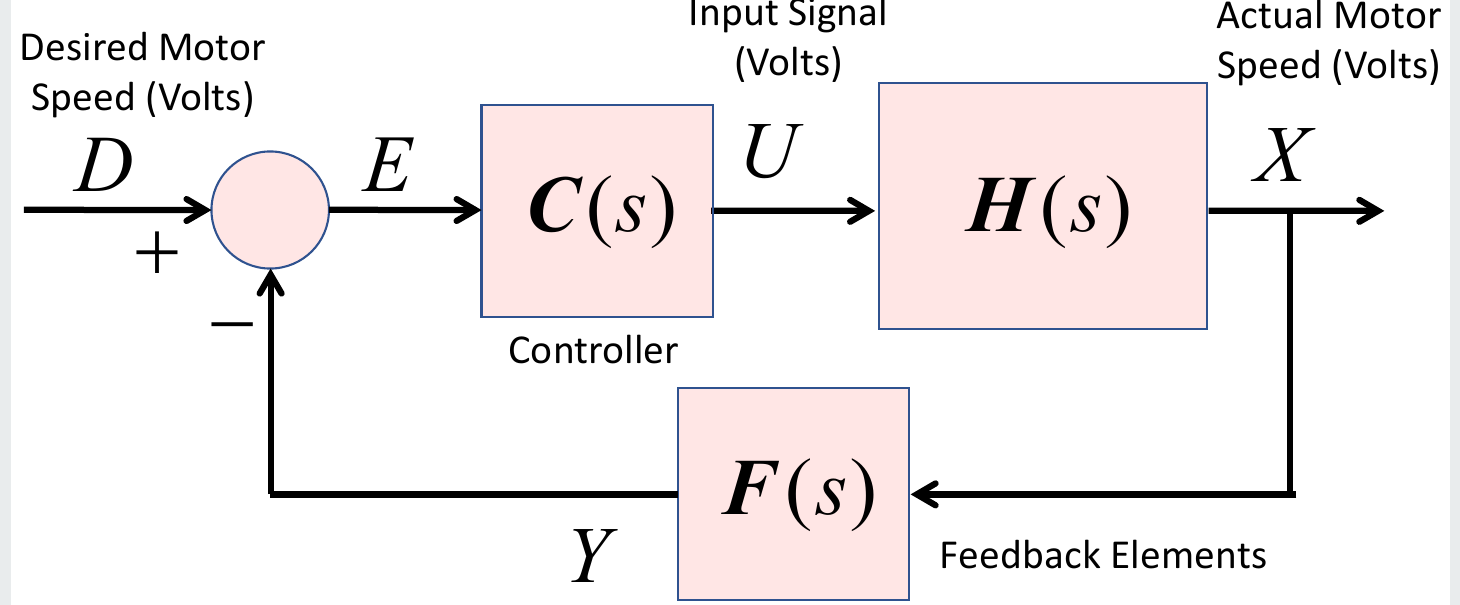
Develop the Closed Loop Transfer Function for the DC motor speed control system in the figure, where is the desired motor speed (volts), the controller, the input signal (volts), the motor, the actual motor speed (volts) and the feedback elements. Either solve using algebra or (saves time) use the rules of block diagram analysis. What condition gives unity steady state gain, and what is the characteristic equation?
Formulas you may need
- Series rule: ; negative feedback rule: (learn this)
- Steady state gain: set ; characteristic equation: denominator (learn this)